GPS-denied navigation solutions for drones and unmanned systems enable reliable positioning, orientation, and autonomous operation when satellite navigation signals are unavailable, degraded, jammed, or spoofed. These technologies support UAVs, UGVs, USVs, and underwater vehicles operating in contested, urban, indoor, and maritime environments.
This page features suppliers of GPS/GNSS-denied navigation solutions, supporting defense operations, search and rescue, infrastructure inspection, industrial robotics, and autonomous surveying.
If you design, build or supply GPS/GNSS-Denied Navigation & Positioning, create a profile to showcase your capabilities and connect with visitors who have an active requirement for your solutions.
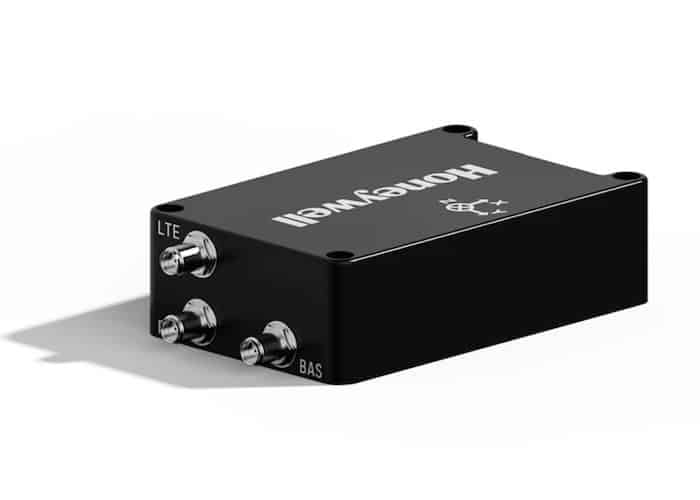
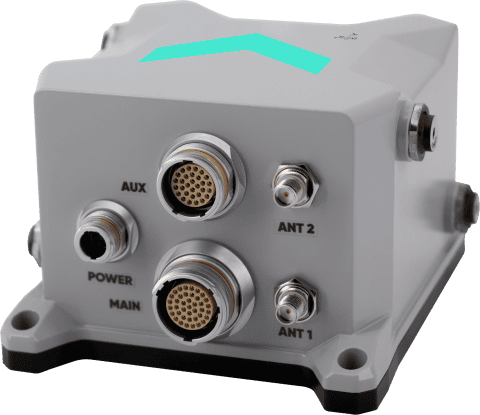
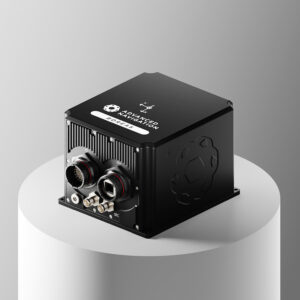
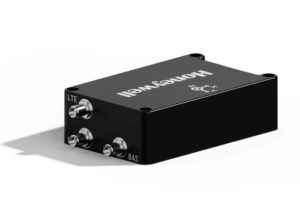
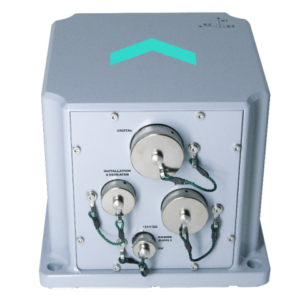
LEO-aided INS for assured PNT in contested domains
LEO-aided INS for assured PNT in contested domains
...O-based timing/navigation, and anti-jam GNSS (with CRPA port) delivers resilient performance across... ... achieves GNSS-denied performance of 80 m RMS position and 2 m/s velocity accuracy. Integrated...
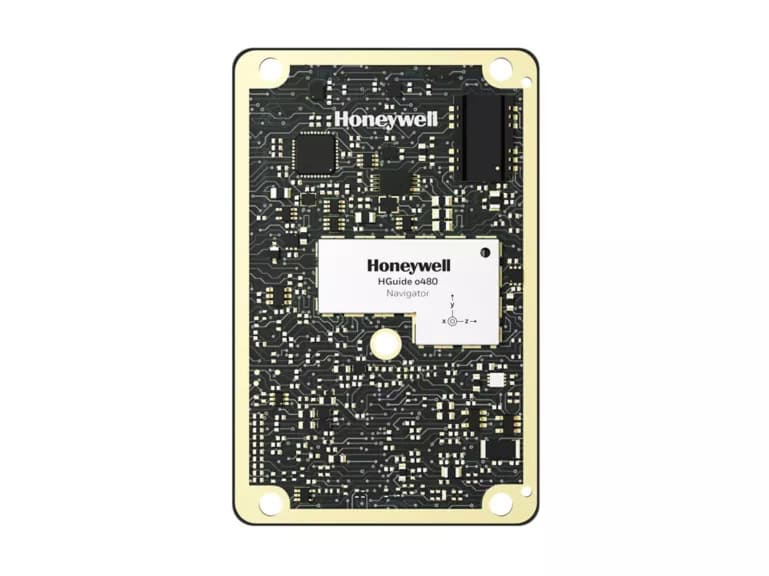
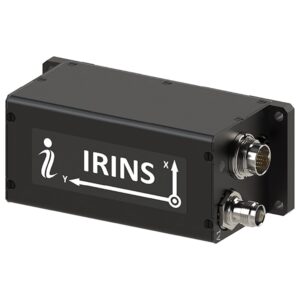
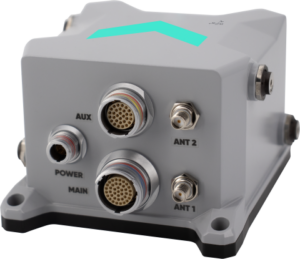
High-accuracy inertial navigation system engineered for GNSS-denied environments
High-accuracy inertial navigation system engineered for GNSS-denied environments
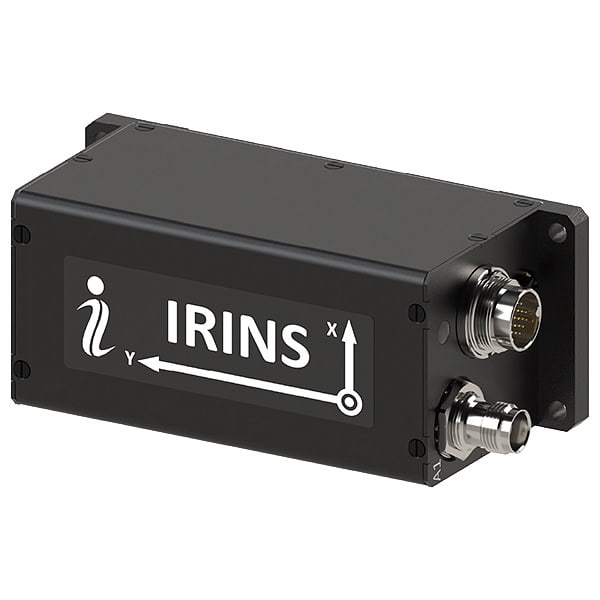
...high-precision navigationsolution designed for unmanned vehicles and autonomous platforms operating... ... VINS Inertial Navigation System delivers precise positioning and orientation for unmanned platforms...
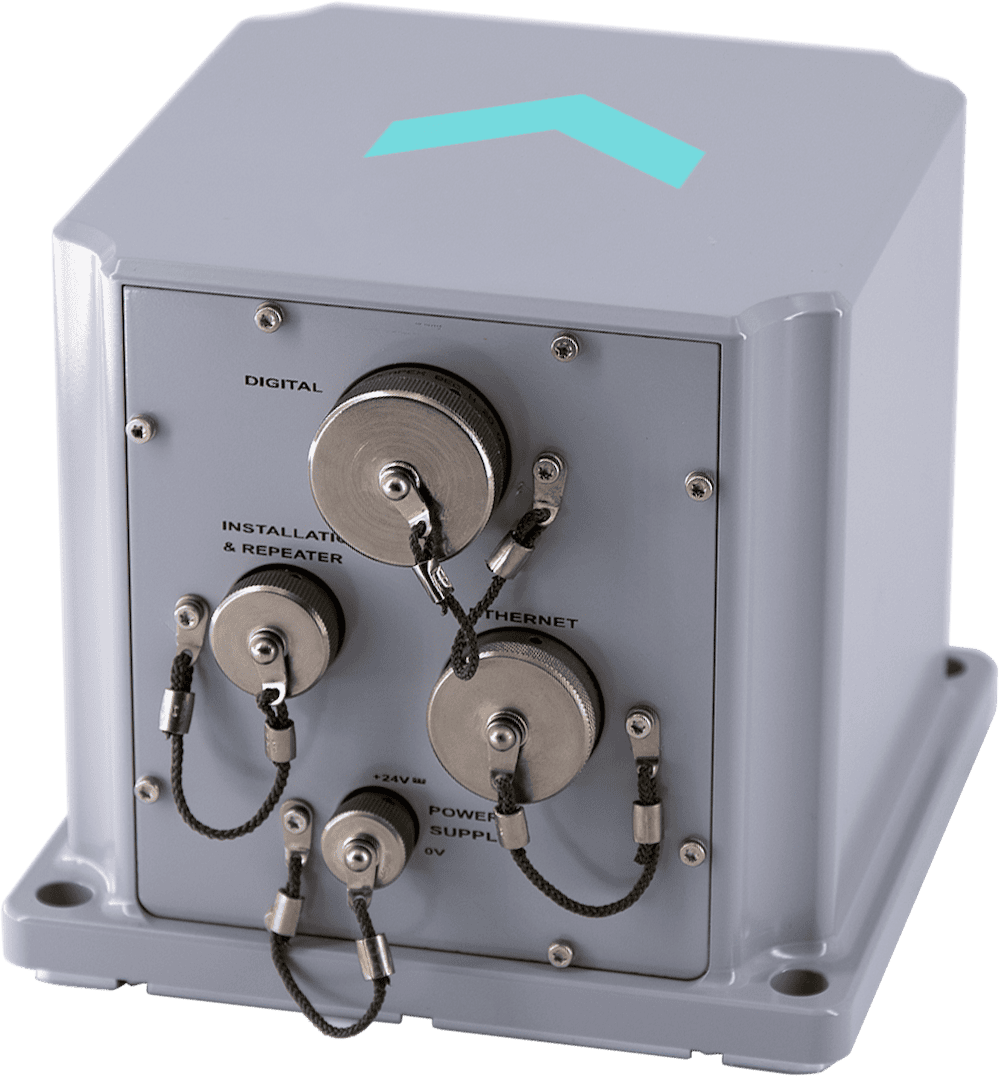
Compact FOG-based AHRS & INS with north-seeking gyrocompass
Compact FOG-based AHRS & INS with north-seeking gyrocompass
...) and Inertial Navigation System (INS) designed for precision navigation in demanding unmanned and... ...nclude defense navigation, guidance, and control systems, as well as mining equipment alignment and...
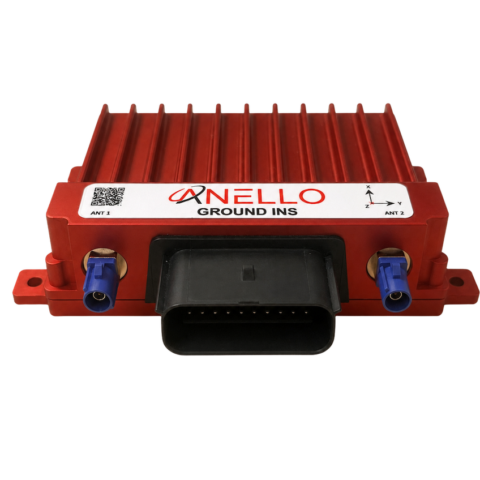
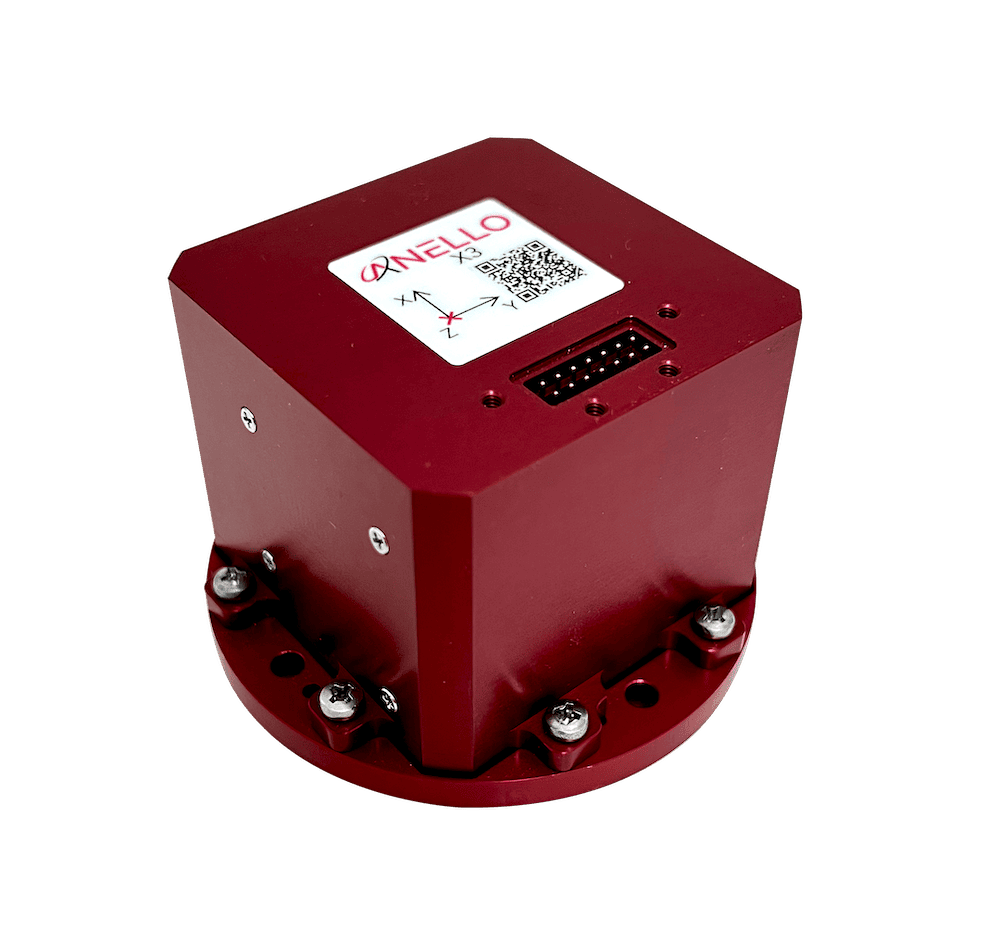
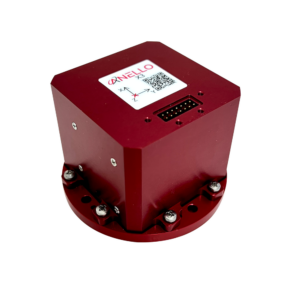
...;s advanced AI solution, the ANELLO X3 can be used to create a robust low-drift and low-noise... ...... PX4 and Ardupilot, enabling precise, low-drift inertial navigation for autonomous aerial...
The Complete Guide to GPS-Denied Navigation Solutions for Drones & Unmanned Systems
Overview by
William Mackenzie
Updated:
Introduction to GNSS/GPS Denied Navigation for Drones & Unmanned Systems
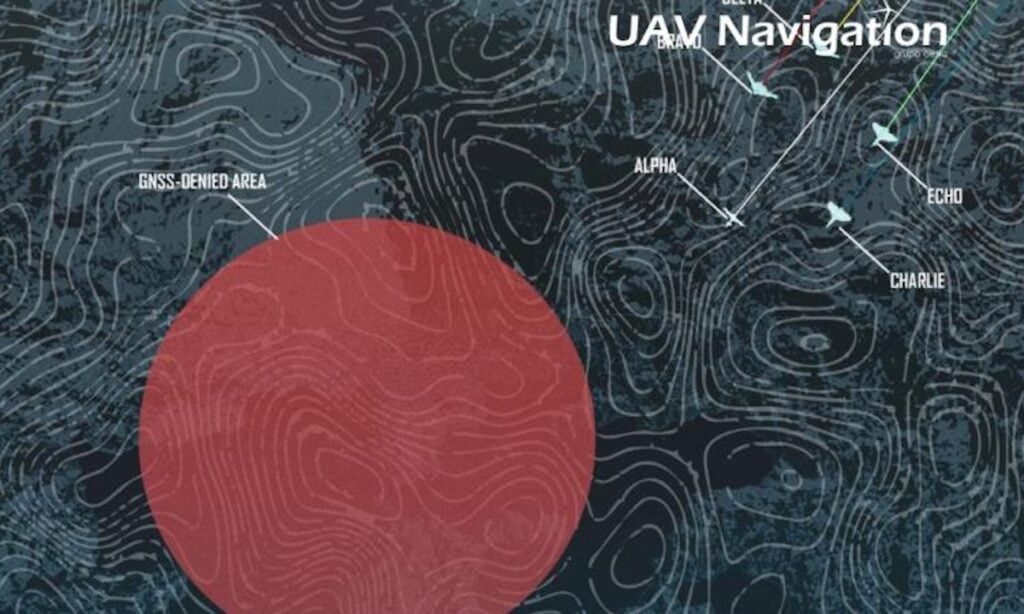
GNSS/GPS-denied navigation and positioning technology enables unmanned systems to determine position, velocity, and orientation without relying on GPS or other satellite navigation signals. These technologies are critical as unmanned aerial, ground, surface, and underwater platforms are increasingly required to operate in GNSS-denied environments where satellite signals are unavailable, degraded, or deliberately disrupted by jamming or spoofing.
By using onboard sensing, processing, and alternative navigation methods, GNSS-denied navigation provides resilient positioning in urban canyons, indoor and subterranean spaces, maritime environments, and contested electromagnetic conditions. This approach supports safe autonomy, mission continuity, and operational reliability when satellite-based navigation is unavailable or unreliable.
Triple-Layered GPS-Denied Navigation for UAVs by Honeywell Aerospace
Where GNSS Denied Navigation is Needed
Defense and Contested Operations
GPS-denied navigation enables assured positioning for unmanned systems operating under GPS jamming, spoofing, and electronic attack. Military UAVs and other platforms rely on these capabilities to maintain navigation continuity in contested airspace and hostile electromagnetic environments.
Urban and Built Environment Autonomy
Autonomous vehicles operating in urban canyons face signal blockage and multipath interference from buildings. GPS-denied navigation solutions enable safe operation for aerial and ground platforms when continuous satellite navigation is unavailable.
Search and Rescue Operations
GNSS-denied navigation enables unmanned systems to operate in indoor, underground, or disaster-affected areas where infrastructure is damaged or unavailable. These capabilities enable effective navigation in collapsed structures, tunnels, and dense urban terrain.
Maritime and Underwater Operations
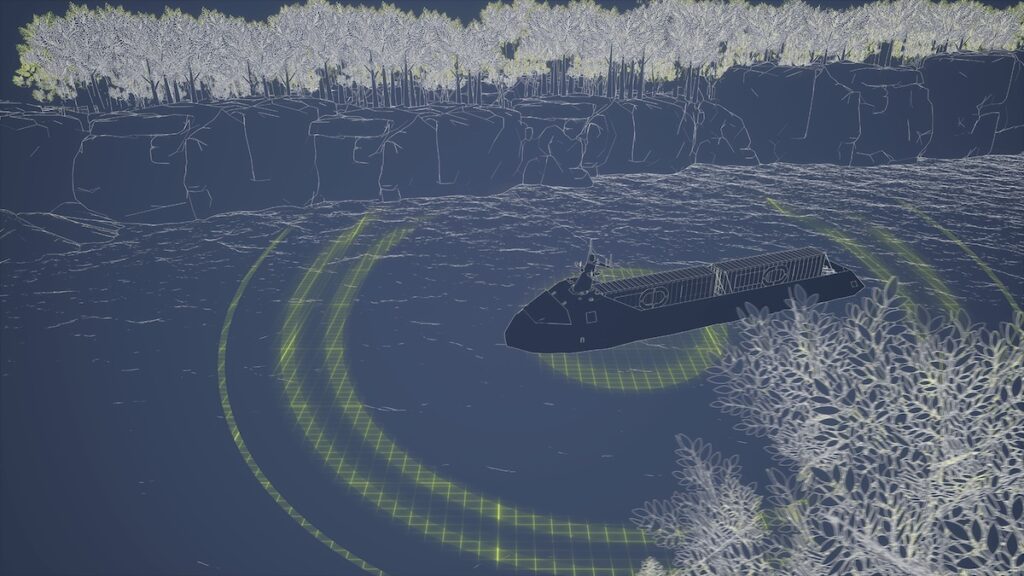
Underwater and near-shore environments inherently lack GNSS availability. Autonomous underwater vehicles and surface platforms rely on GNSS-denied navigation methods to maintain accurate positioning during long-duration missions.
Commercial and Industrial Autonomy
Industrial applications such as warehouse robotics, mining operations, offshore activities, and infrastructure inspection benefit from navigation without GNSS. These environments demand reliable positioning independent of external signals to improve safety and operational efficiency.
Types of GNSS Denied Navigation Systems
Inertial Navigation Systems
Inertial navigation systems provide self-contained positioning by calculating motion from onboard inertial sensors. These systems operate independently of external signals, making them a core capability for GNSS-denied navigation across unmanned air, ground, surface, and underwater platforms.
Inertial Measurement Units
Inertial measurement units combine accelerometers and gyroscopes to measure linear acceleration and rotational motion. IMUs are foundational components of GPS-denied navigation technology, providing high-rate data for dead reckoning, attitude estimation, and motion tracking.
GNSS/INS Integrated Navigation Systems
GNSS/INS systems tightly integrate inertial navigation with satellite navigation when available, enabling seamless transitions between GNSS-aided and GNSS-denied operations. In contested or degraded environments, the inertial subsystem maintains continuous navigation while filtering and rejecting corrupted GNSS inputs, making GNSS/INS a primary architecture for resilient and assured navigation.
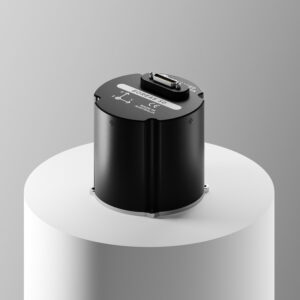
Marins M5 GNSS-Denied INS by Exail
Chip Scale Atomic Clocks
Chip-scale atomic clocks provide highly stable onboard timing references that reduce inertial navigation drift during extended GNSS outages. When integrated with GNSS/INS and inertial systems, these clocks improve long-duration accuracy and timing resilience without external synchronization.
Vision-Based Navigation Systems
Vision-based navigation systems use optical cameras and onboard processing to estimate motion by tracking visual features in the environment. These systems are well-suited to GPS-denied navigation for drones in urban, indoor, and low-altitude environments with sufficient visual structure.
Simultaneous Localization and Mapping Systems
Simultaneous localization and mapping systems enable unmanned platforms to build maps of unknown environments while estimating their position within them. SLAM systems support autonomous navigation in GNSS-denied conditions where prior maps or absolute references are unavailable.
Lidar Navigation Systems
Lidar navigation systems use active laser sensing to generate three-dimensional environmental data for localization and mapping. These systems support high-accuracy navigation in GPS-denied environments, including low-light or visually degraded conditions.
Radar Navigation Systems
Radar navigation systems provide robust sensing and localization in environments affected by weather, dust, smoke, or poor visibility. Radar-based navigation is commonly used on maritime and aerial platforms that require long-range, all-weather, GNSS-denied capability.
Magnetic Navigation Systems
GPS-Denied GNSS INS by ANELLO Photonics
Magnetic navigation systems leverage spatial variations in Earth’s magnetic field to enable positioning without GNSS. When paired with magnetic maps, these systems offer passive navigation in environments where other sensing modalities are limited.
Terrain Referenced Navigation Systems
Terrain-referenced navigation systems estimate position by correlating onboard sensor data with stored digital terrain or elevation maps. These systems are effective for low-altitude aerial and ground platforms operating in GNSS-denied regions with well-characterized terrain.
Celestial Navigation Systems
Celestial navigation systems determine position by observing stars or other celestial references. These systems support long-duration GNSS-denied missions where terrestrial navigation cues and satellite signals are unavailable.
Multi-Sensor Navigation Systems
Multi-sensor navigation systems integrate inertial, GNSS/INS, visual, lidar, radar, magnetic, and terrain-based inputs. By combining complementary sensing modalities, these systems improve robustness and continuity across diverse GNSS-denied environments.
Sensor Fusion Software
Sensor fusion software combines data from multiple navigation sensors into a unified navigation solution. These algorithms are essential for managing uncertainty, correcting drift, and maintaining reliable GPS-denied positioning during GNSS outages or attacks.
Assured and Resilient Navigation Systems
Assured navigation systems are designed to operate through GNSS jamming, spoofing, and signal degradation. These GPS-denied solutions emphasize integrity monitoring, fault detection, and resilient performance to support mission-critical unmanned operations in contested environments.
Standards & Operational Requirements
GPS-denied navigation systems for drones and unmanned platforms may be subject to software, hardware, environmental, and operational requirements depending on their architecture, intended application, and certification needs. Relevant standards, protocols, and integration frameworks include:
RTCA DO-178C: Provides guidance for airborne software development assurance, including verification, validation, and lifecycle processes for safety-critical aviation applications.
RTCA DO-254: Addresses development assurance for airborne electronic hardware, including complex programmable components used in navigation and control systems.
RTCA DO-160: Defines environmental test procedures for airborne equipment, covering conditions such as temperature, vibration, shock, electromagnetic interference, and power input variations.
ASTM F3269: Addresses methods for evaluating autonomous capabilities in unmanned aircraft systems, with relevance to autonomy performance and operational assurance where applicable.
MAVLink: A lightweight communication protocol used to exchange navigation, positioning, status, and control data between compatible UAV autopilots, onboard computers, and ground control systems.
ROS 2: Robotics middleware supporting the integration of localization, mapping, sensor fusion, and autonomous navigation software across unmanned platforms.
Compliance requirements depend on the unmanned platform, operating environment, and regulatory framework, with navigation performance and reliability assessed against the needs of the intended mission.
Selecting GNSS/GPS Denied Navigation Solutions
Selecting GPS-denied navigation solutions requires consideration of the unmanned platform, expected operating conditions, positioning requirements, and available sensor inputs. The following factors help determine which navigation technologies and system architectures are suitable for a particular application.
Selection Factor
Key Considerations
Unmanned Platform Type and Mission Profile
Navigation requirements differ between multirotor and fixed-wing UAVs, ground robots, USVs, and underwater vehicles. Mission duration, platform dynamics, operating speed, and autonomy requirements influence system selection.
Required Navigation Accuracy and Drift Tolerance
Evaluate allowable position error, heading accuracy, and accumulated drift during operation without GNSS. Applications requiring precise positioning may need external references or sensor-based localization updates.
Expected Duration of GNSS Unavailability
Short GNSS interruptions may be managed through inertial dead reckoning, while extended outages typically require additional positioning inputs to limit accumulated navigation errors.
Operating Environment and Available Visual Features
Indoor environments, urban areas, open terrain, and maritime settings present different localization challenges. Visual and LiDAR-based systems depend on detectable environmental features, while radar and inertial solutions can support navigation under different sensing conditions.
Sensor Configuration and Environmental Suitability
Consider the availability and compatibility of cameras, IMUs, LiDAR, radar, and alternative positioning sensors. Lighting, visibility, vibration, temperature, and electromagnetic interference can influence sensor performance.
Absolute Versus Relative Positioning Requirements
Relative navigation estimates movement from a previous position, while absolute localization requires an external reference, known landmarks, or suitable map data. Mission requirements determine whether one or both capabilities are necessary.
Size, Weight, and Power (SWaP) Constraints
Assess the physical dimensions, mass, electrical power requirements, and thermal characteristics of navigation hardware, particularly for compact UAVs and other payload-constrained platforms.
Onboard Processing and Data Interfaces
Evaluate computing requirements, navigation update rates, communication protocols, and compatibility with existing flight controllers, autonomous control systems, and sensor fusion software.
Emerging Developments in GNSS Denied Navigation Technology
Advances in sensor technology, onboard computing, and navigation algorithms are improving the performance of GPS-denied navigation technology for drones and other unmanned systems. Key development areas include:
Advanced Multi-Sensor Fusion: Integration of visual, inertial, LiDAR, radar, and alternative positioning measurements to improve localization accuracy and maintain navigation continuity when individual sensors become unreliable.
Compact High-Performance Inertial Sensors: Improvements in inertial sensor stability, miniaturization, and power efficiency are supporting more capable navigation systems for smaller UAVs and autonomous platforms.
Resilient Navigation Architectures: Adaptive sensor selection, navigation integrity monitoring, and fault-tolerant localization algorithms enable unmanned systems to respond to GNSS degradation, interference, and sensor failures.
AI-Assisted Visual Navigation: Machine learning techniques are being applied to visual feature recognition, environmental interpretation, and map-based localization to support autonomous navigation in complex environments.
These developments are supporting greater positioning resilience, reduced dependence on satellite navigation, and more reliable autonomous operation across diverse unmanned platforms.
Advanced Navigation highlights its inertial-centric navigation architecture during U.S. Army APEX trials, recording 0.012% final dead-reckoning error over 65 km under GNSS jamming conditions
A successful flight demonstration of Honeywell Aerospace's compact navigation system proves that small tactical drones can maintain precise timing and positioning data inside satellite denied or hostile contested military environments
Forcys details how Sonardyne’s SPRINT-Nav and Vigilant FLS support autonomous USVs with navigation accuracy and situational awareness when GNSS data is denied or deliberately spoofed
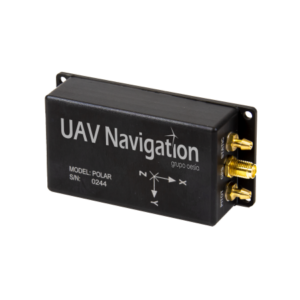
UAV Navigation-Grupo Oesía Director and CTO Miguel Ángel de Frutos Carro discusses resilient navigation, communications and onboard autonomy for UAV operations in GNSS-denied environments
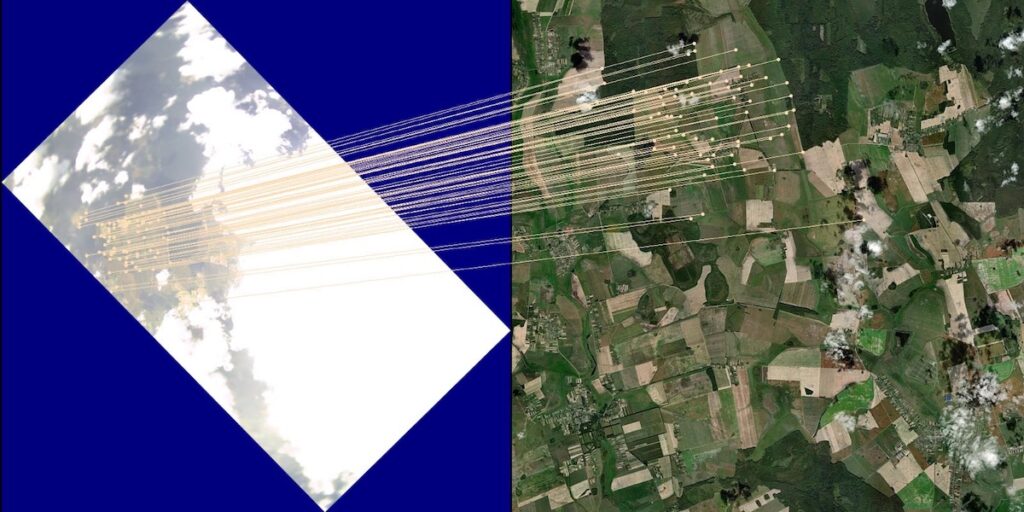
UAVOS has tested NAVAI, a vision-based navigation module that uses neural networks, real-time camera imagery and pre-loaded terrain maps to provide an additional positioning input for UAS operating in GNSS-degraded environments
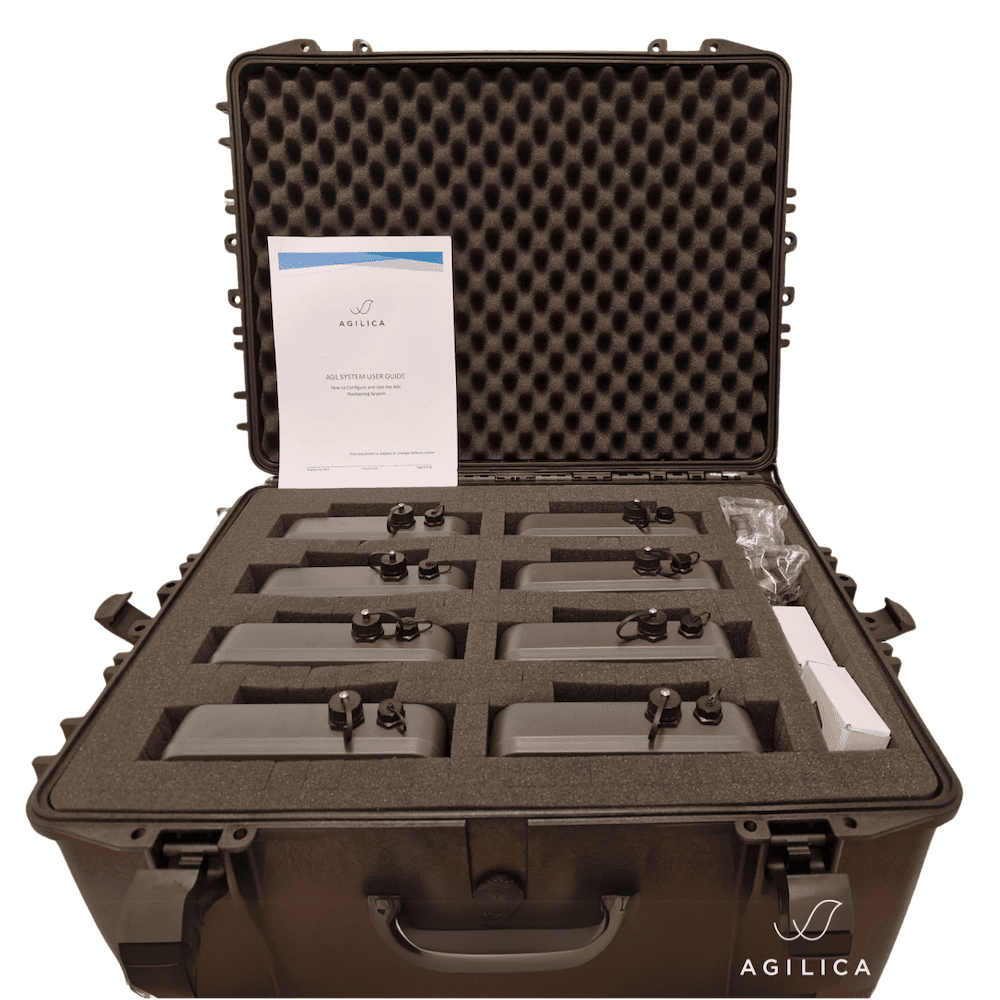
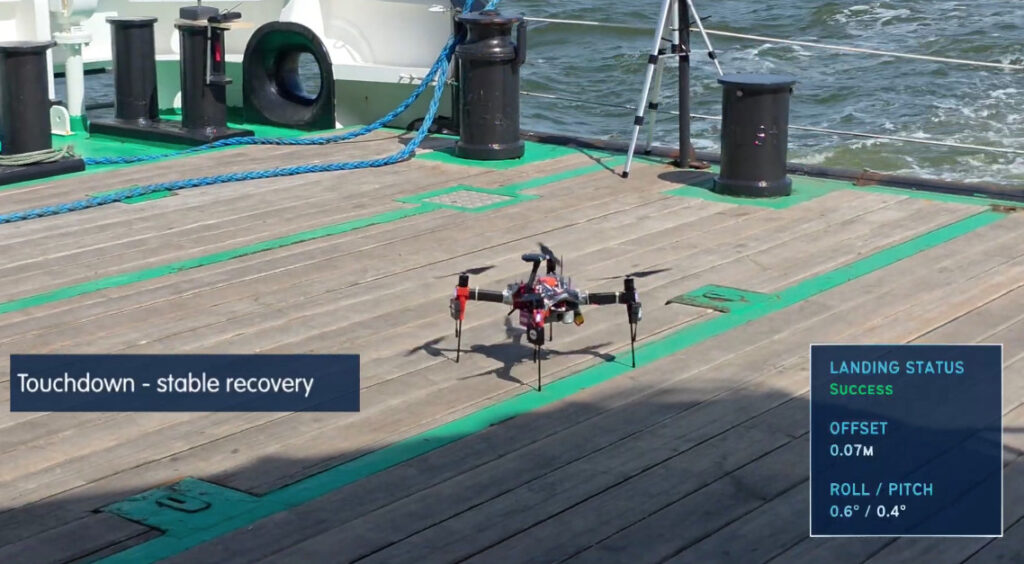
Agilica’s beacon-based Ultra-Wideband positioning system has supported 30 successful maritime uncrewed aerial vehicle recoveries to a vessel travelling at approximately 10 knots, with no failed recoveries recorded during the trial sequence
Advanced Navigation's resilient inertial navigation solutions are designed to maintain precise drone tracking and engagement capabilities during electronic warfare conditions and total GPS denial to ensure mission success
Septentrio's comprehensive product portfolio utilizes advanced anti-jamming and anti-spoofing technology and also includes Blue UAS Framework-listed GNSS receivers
The latest unmanned systems news, straight to your inbox.
Get our weekly roundup of technology developments, new products and industry news.
THANK YOU FOR SIGNING UP
Thanks for joining us. Check your inbox.
We've sent you an email. Click the confirmation link to complete your subscription to the weekly eBrief. In the meantime, explore the latest news, suppliers and technologies on UST.
Advancing Unmanned Systems Through Strategic Collaboration
UST works with major OEMs to foster collaboration and increase engagement with SMEs, to accelerate innovation and drive unmanned systems capabilities forward.